OriginCar Intelligent Robot Open-Source Kit
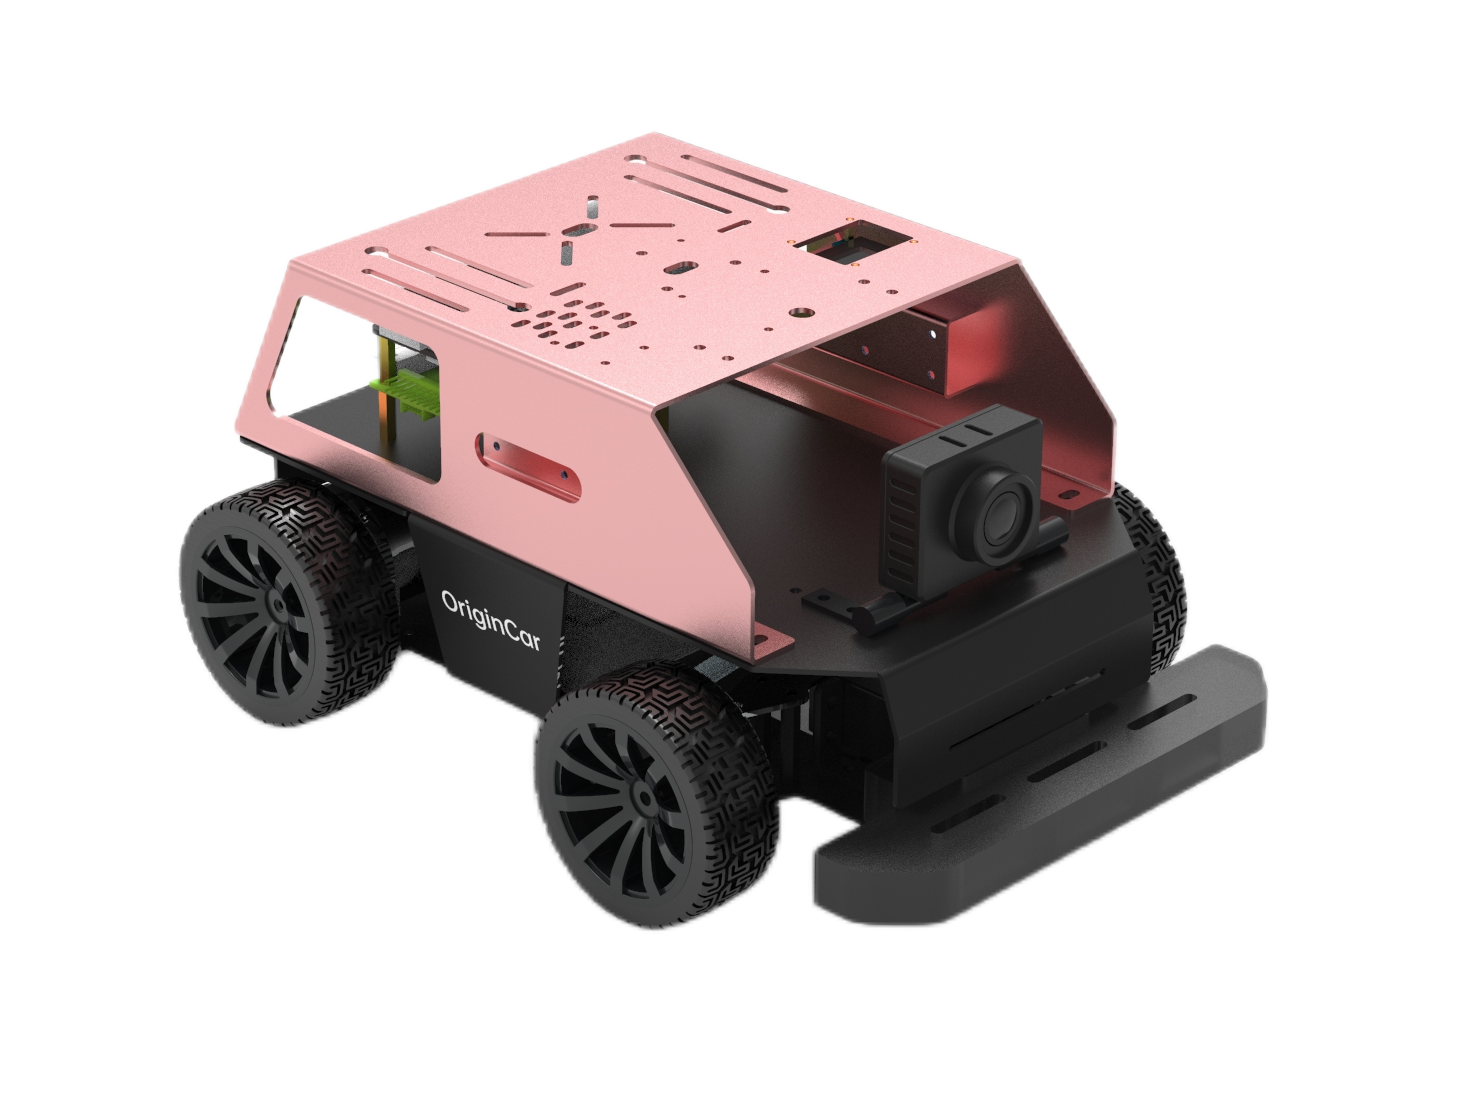
OriginCar
OriginCar is an intelligent robot and, more than that, a robot product born of passion. It is equipped with the D-Robotics development kit — RDK X3/RDK X5 — and is compatible with many application features in the ROS/ROS2 ecosystem. As a member of the Origin intelligent robot series, it aims to let more developers explore the passion hidden deep in their hearts.
Technical Specifications
| Main configuration item | OriginCar | OriginCar Pro | OriginCar EDU |
|---|---|---|---|
| Product image | |
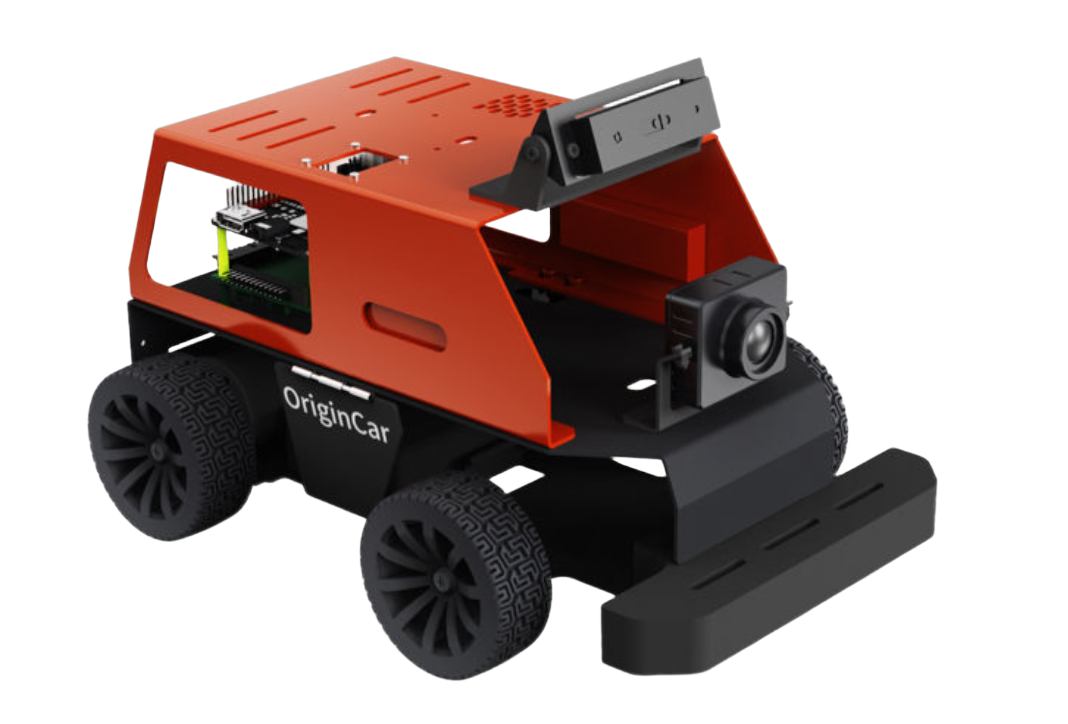 |
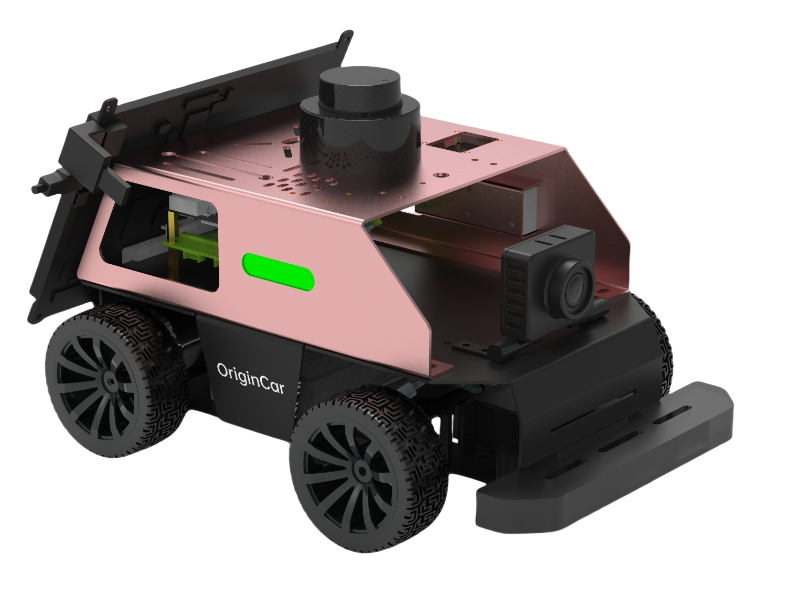 |
| Basic body parameters | Dimensions ≥276x189x150mm Net weight ≥2.4kg. |
Dimensions ≥276x189x150mm Net weight ≥2.4kg. |
Dimensions ≥276x189x150mm Net weight ≥2.4kg. |
| Main controller system | Application processor: • CPU: Quad-core Arm® Cortex®-A53@1.5GHz • BPU: Dual-core@1GHz, equivalent computing power 5 TOPS • Memory: 4GB LPDDR4 RAM • Storage: 32GB (TF card) Motion controller: • MCU: STM32F407VET6 • IMU chip: onboard MPU6050 |
Application processor: • CPU: Octa-core Arm® Cortex®-A55@1.5GHz • BPU: 1xBayers BPU, with 10TOPS computing power • Memory: 8GB LPDDR4 RAM • Storage: 32GB (TF card) Motion controller: • MCU: STM32F407VET6 • IMU chip: onboard MPU6050 |
Application processor: • CPU: Octa-core Arm® Cortex®-A55@1.5GHz • BPU: 1xBayers BPU, with 10TOPS computing power • Memory: 8GB LPDDR4 RAM • Storage: 32GB (TF card) Motion controller: • MCU: STM32F407VET6 • IMU chip: onboard MPU6050 |
| Expansion configuration | • Maximum number of encoder motors that can be driven: 4 • Number of PWM servos that can be driven: 6 • Human-machine interaction interfaces: buttons, buzzer, OLED display • Human-machine interaction: GMR (giant magnetoresistance) 500-line encoder motor * 2, camera mount, digital servo |
• Maximum number of encoder motors that can be driven: 4 • Number of PWM servos that can be driven: 6 • Human-machine interaction interfaces: buttons, buzzer, OLED display • Human-machine interaction: GMR (giant magnetoresistance) 500-line encoder motor * 2, camera mount, digital servo |
• Maximum number of encoder motors that can be driven: 4 • Number of PWM servos that can be driven: 6 • Human-machine interaction interfaces: buttons, buzzer, OLED display • Human-machine interaction: GMR (giant magnetoresistance) 500-line encoder motor * 2, camera mount, digital servo, touchscreen HDMI interface (size: 164.5x124x8mm; resolution: 1024x600px) |
| Monocular camera | • Resolution: 1080P • FOV: H69°/V55°/D82° • Frame rate: 25 fps • Driver mode: supports UVC, driver-free plug-and-play |
• Resolution: 1080P • FOV: H69°/V55°/D82° • Frame rate: 25 fps • Driver mode: supports UVC, driver-free plug-and-play |
• Resolution: 1080P • FOV: H69°/V55°/D82° • Frame rate: 25 fps • Driver mode: supports UVC, driver-free plug-and-play |
| LiDAR (TOF) | / | / | • Sampling frequency: 4500hz • Scanning frequency: 6-12HZ adjustable • Ranging accuracy: ±3cm (0~6m) • Angular resolution: 0.48°-0.96° adjustable •Output data resolution: 15mm •Measurement radius: ≤25m • Scanning angle: 360° • Supported: ROS1/ROS2 STM32 acquisition |
| Depth camera | / | • Overall dimensions: 61x18x14.3mm • Depth accuracy: 8mm@1m • Depth precision: 3mm@0.5m, 7mm@1m • Depth resolution/frame rate: 640x400/12fps/74°x51° • Color resolution/frame rate: 640x400/12fps/74°x51° • IR resolution/frame rate: 640x400/12fps/74°x51° • Working distance: 15 ~ 300cm • Depth data format: Raw16 • Color data format: NV12 |
• Overall dimensions: 61x18x14.3mm • Depth accuracy: 8mm@1m • Depth precision: 3mm@0.5m, 7mm@1m • Depth resolution/frame rate: 640x400/12fps/74°x51° • Color resolution/frame rate: 640x400/12fps/74°x51° • IR resolution/frame rate: 640x400/12fps/74°x51° • Working distance: 15 ~ 300cm • Depth data format: Raw16 • Color data format: NV12 |
| Battery life | 2 ~ 4 hours • Battery capacity: 2600 mAh • Charger: 12.6 V 1A charger |
2 ~ 4 hours • Battery capacity: 2600 mAh • Charger: 12.6 V 1A charger |
2 ~ 4 hours • Battery capacity: 2600 mAh • Charger: 12.6 V 1A charger |
| Operating system | • Operating system: Ubuntu 20.04 (Server) • Robot framework: ROS2 Foxy • Development platform: TogetheROS 2.0.2 |
• Operating system: Ubuntu 22.04 (Server) • Robot framework: ROS2 Humble • Development platform: TogetheROS 3.0.0 |
• Operating system: Ubuntu 22.04 (Server) • Robot framework: ROS2 Humble • Development platform: TogetheROS 3.0.0 |
Link Summary
-
Forum discussion: https://www.guyuehome.com/interlocution?id=1826932316801544194
-
D-Robotics developer community: https://developer.d-robotics.cc/
-
Purchase link: https://b38zy.xetslk.com/s/4p0Q6a
-
Matching map kit purchase link: https://zyesr.xetslk.com/s/23NfLQ
-
National University Students Intelligent Car Competition — Smart Healthcare event resource download link: Download link (extraction code GYH1)
-
Code repository: https://gitee.com/Ly0330/origincar